Task
Sets the goal and the order of work: the tables to serve, the tubes to prepare, the order to deliver.
FIXED FOR EVERY MODEL
Same robots, same situations, same controllers. Only the decision model changes. Pick a model and watch it decide, live in your browser.
robojev bench is the benchmark; Jev, d1, Decision-1, GPT-6 Luna, Solar Flash and robo-jev are models you can run in it.
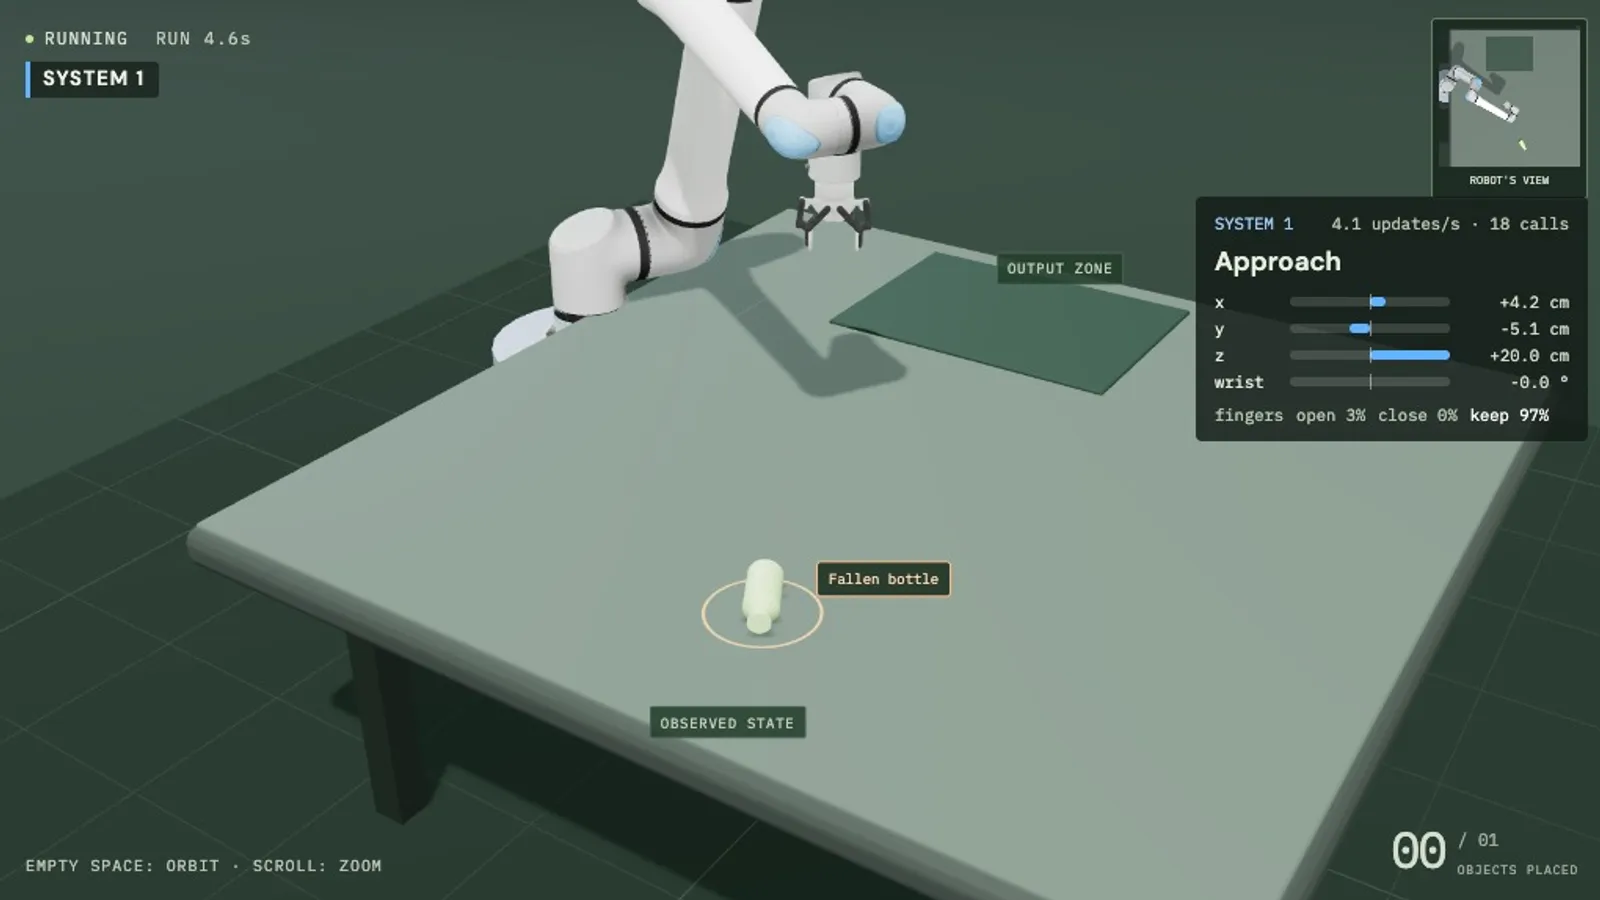 Rule vs System 1 Move a block or tip a bottle mid-run, and watch a fixed rule and System 1 meet the same surprise.TESTSFollowing a part that moves or tips over mid-task.
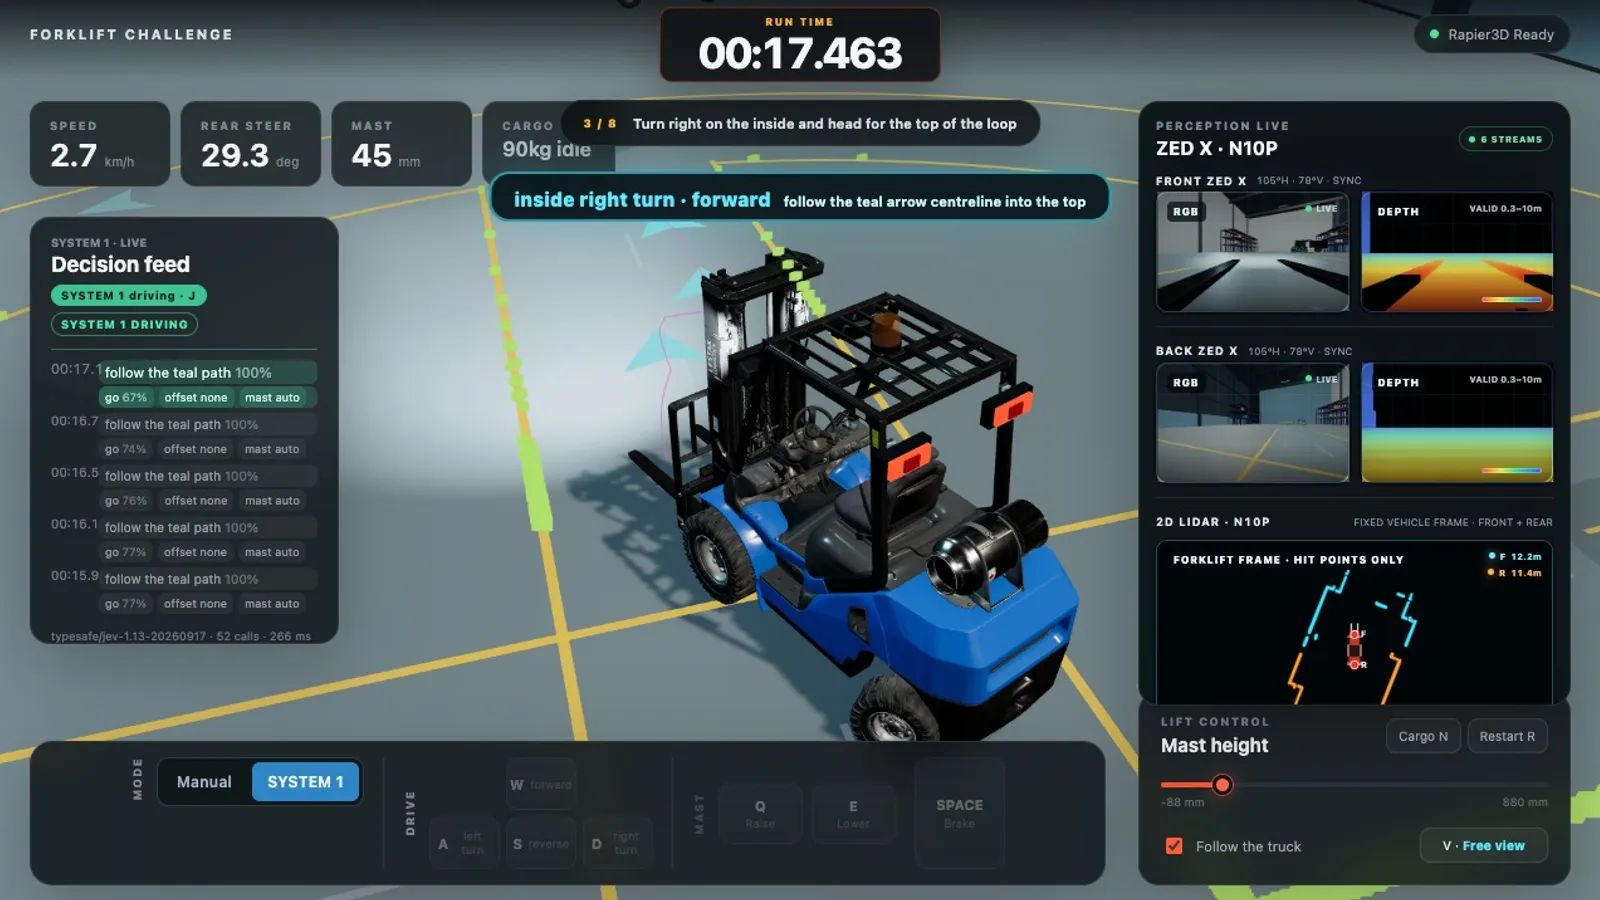 System 1 drives Hand the truck to System 1 on a licence-exam course, or take the wheel yourself.TESTSLane and docking calls on an exam course.
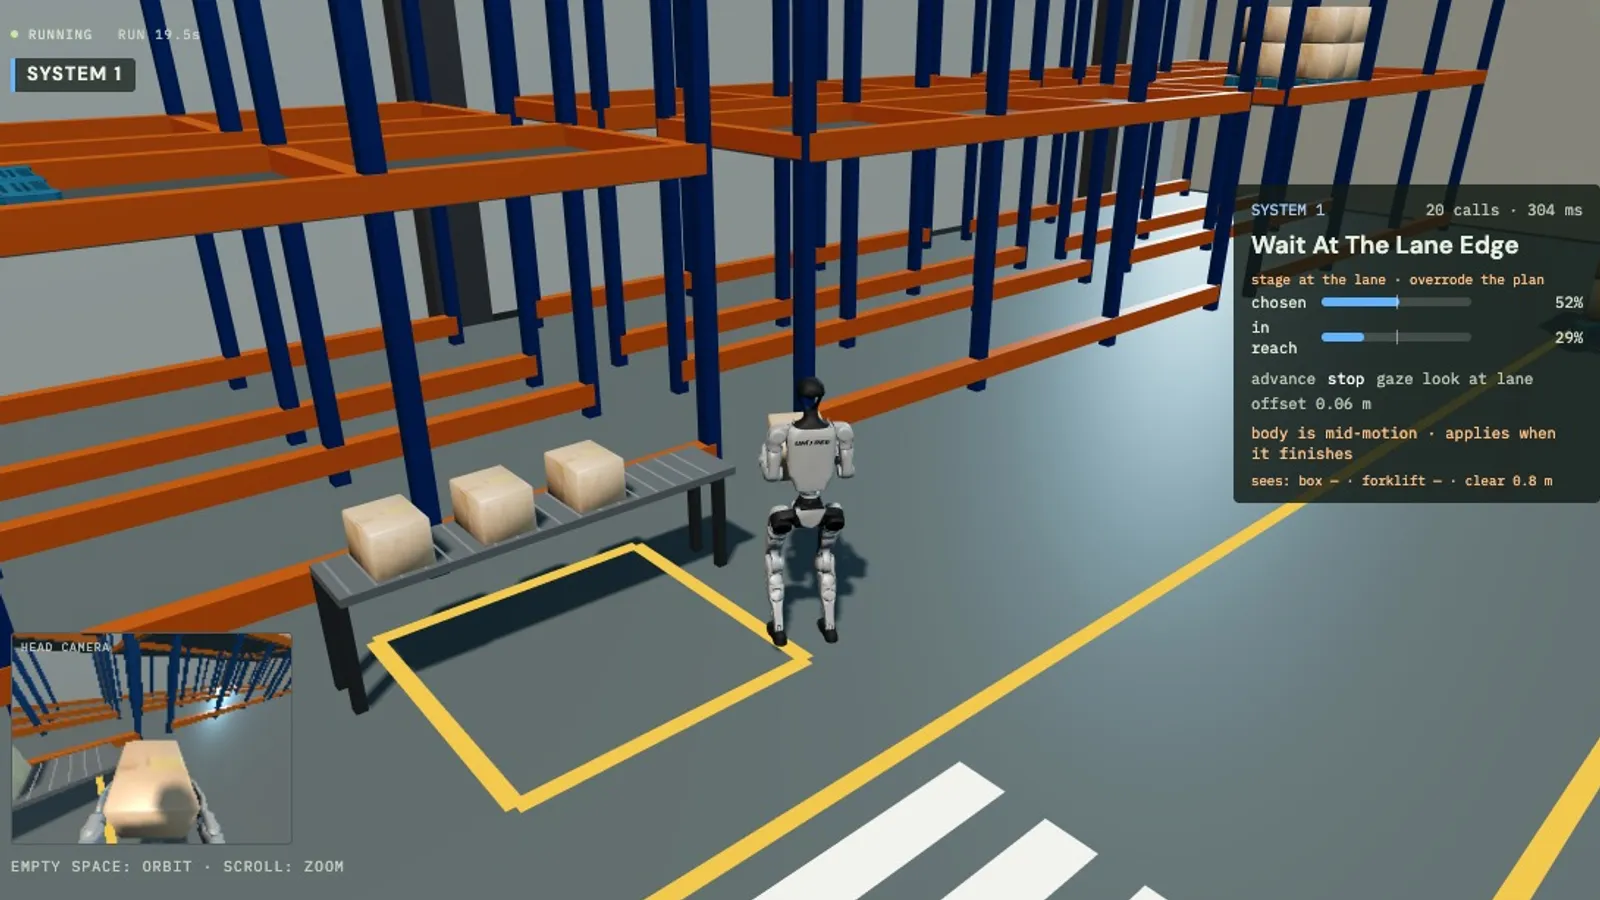 Chooses where to be A G1 carries cartons across a forklift’s lane; watch System 1 decide when to cross and when to wait.TESTSWhether to cross a forklift’s lane, or wait.
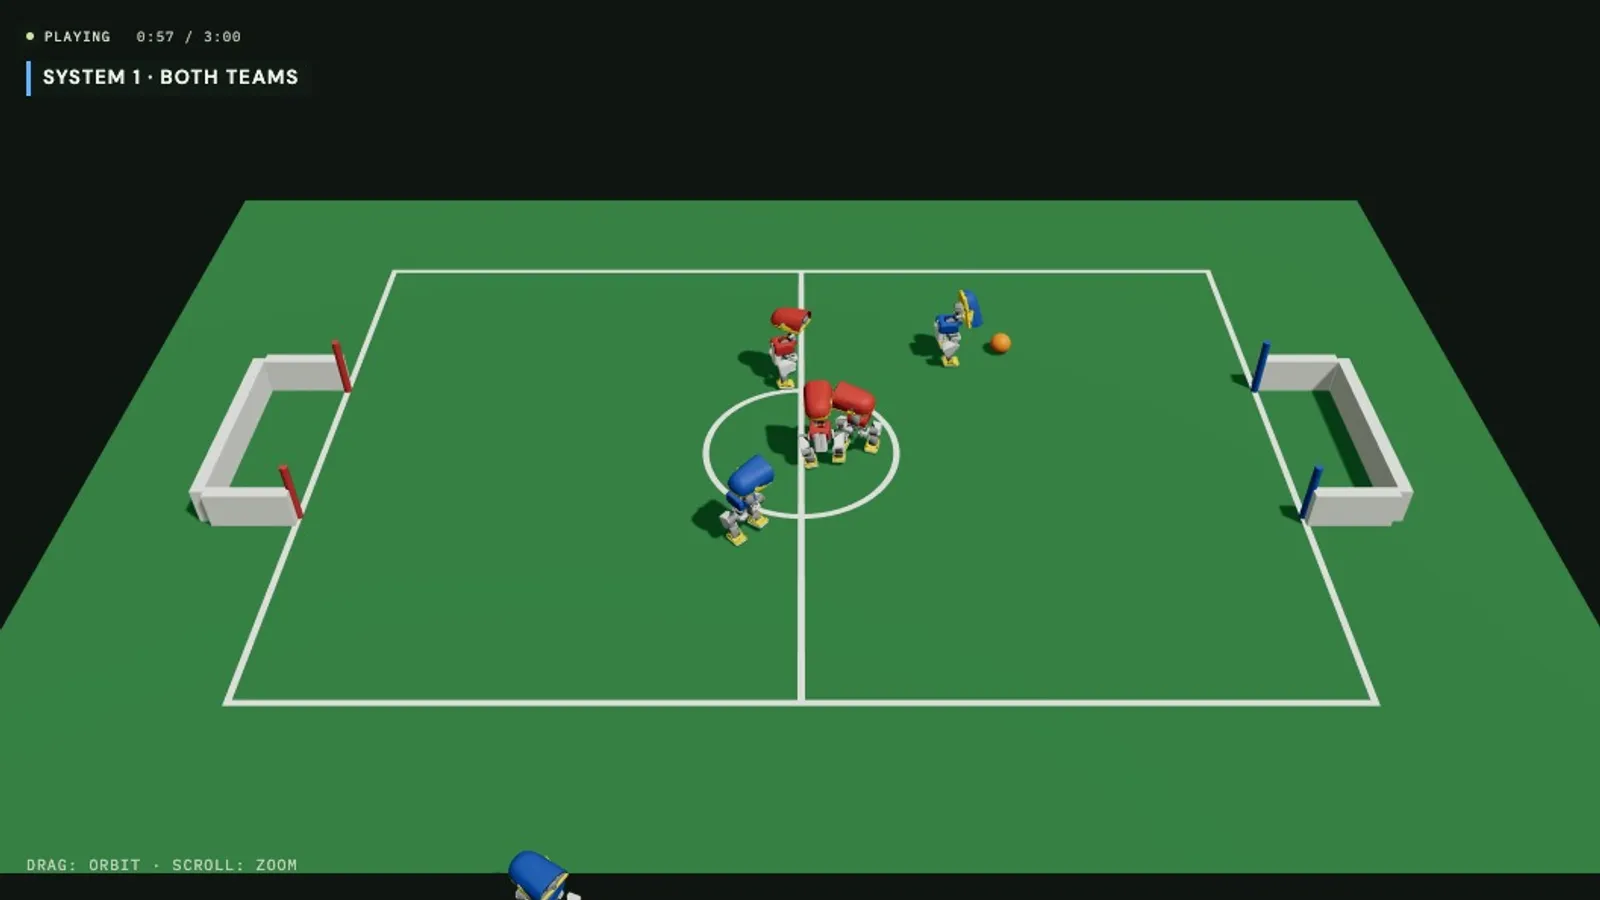 Three a side Kick off a three-minute match; one call a second moves every duck on both teams.TESTSEvery move of six robots, once a second.
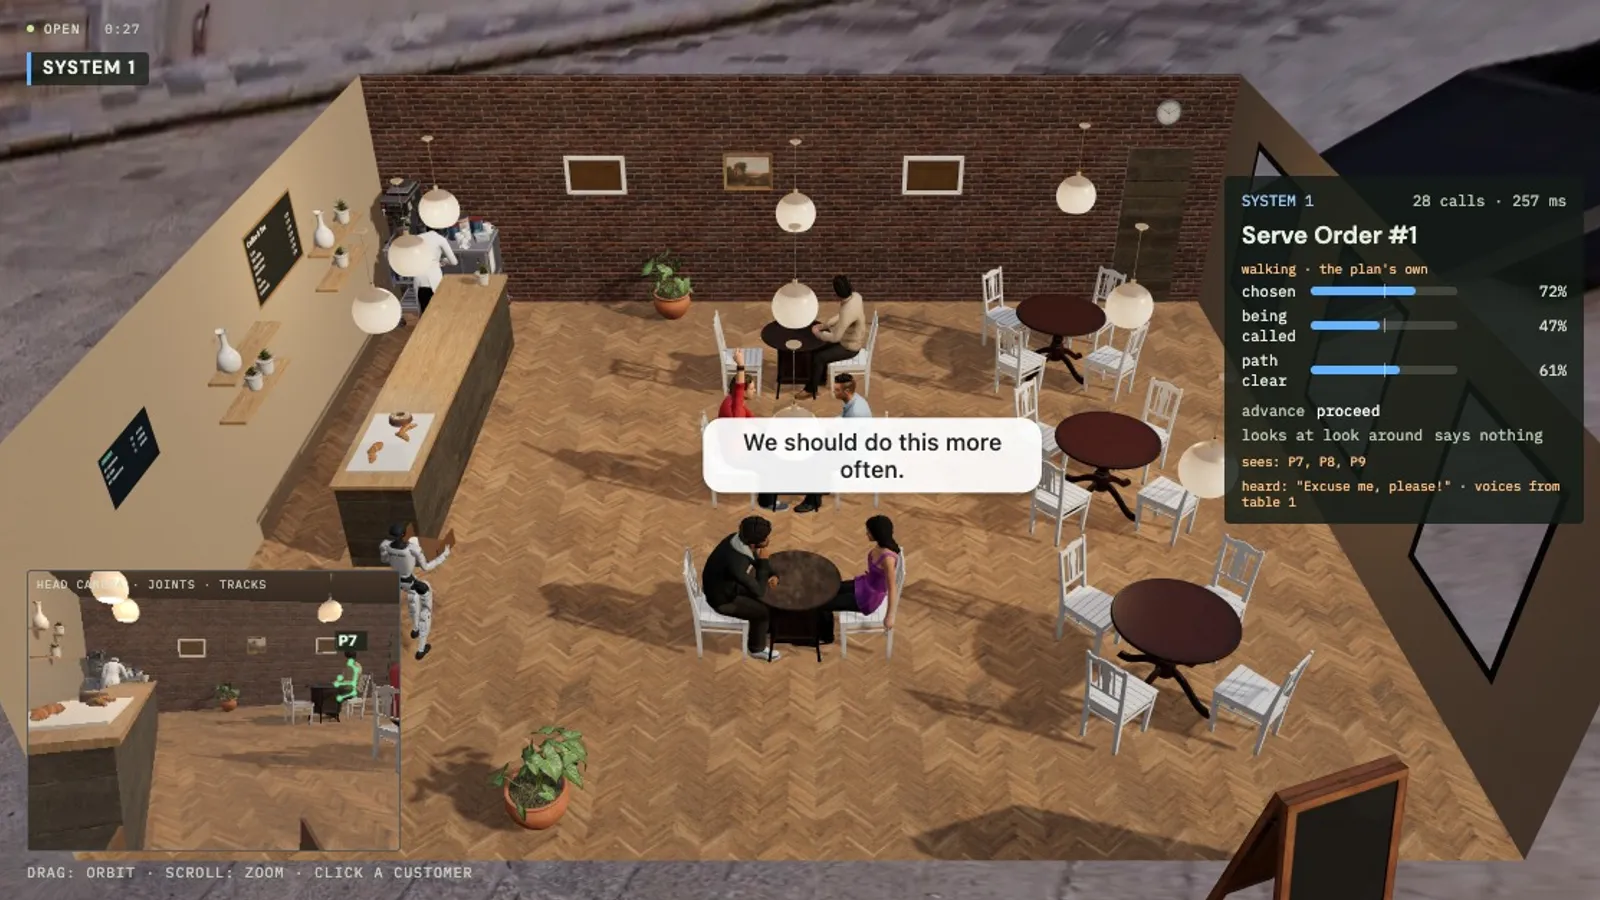 A waiter that reads the room Click a customer to have them order a drink, wave or call out, and see whom the waiter serves.TESTSNoticing who is calling, and what they want.
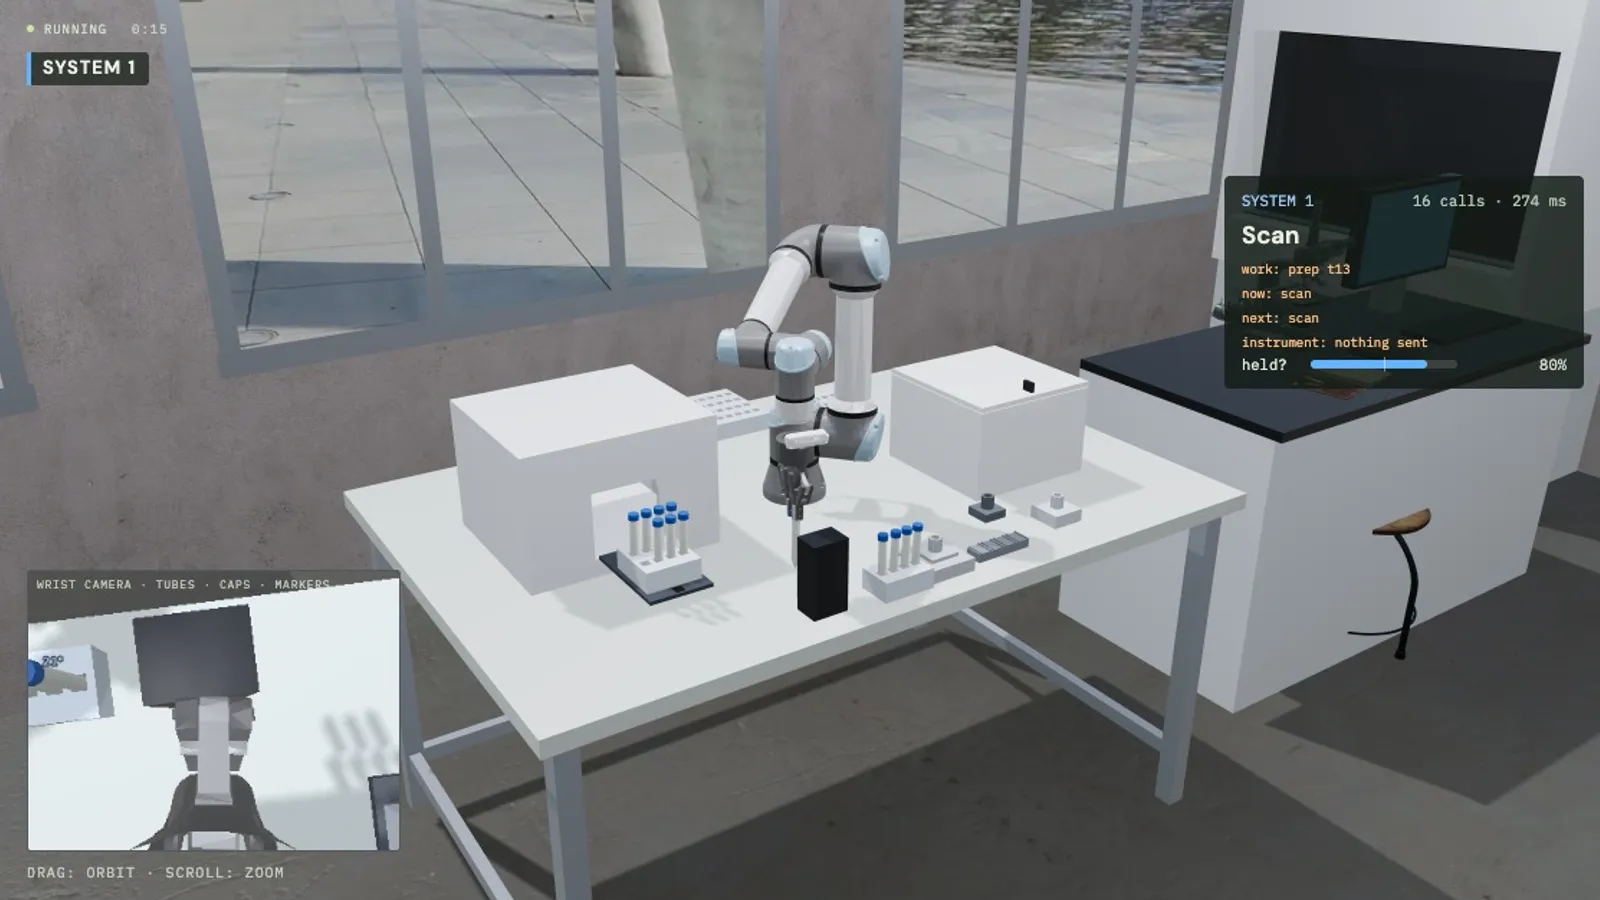 Runs the tube cell Watch System 1 scan, weigh, spin, uncap, aliquot and recap a day of sample tubes — and decide what to set aside.TESTSSpotting an odd sample and setting it aside.
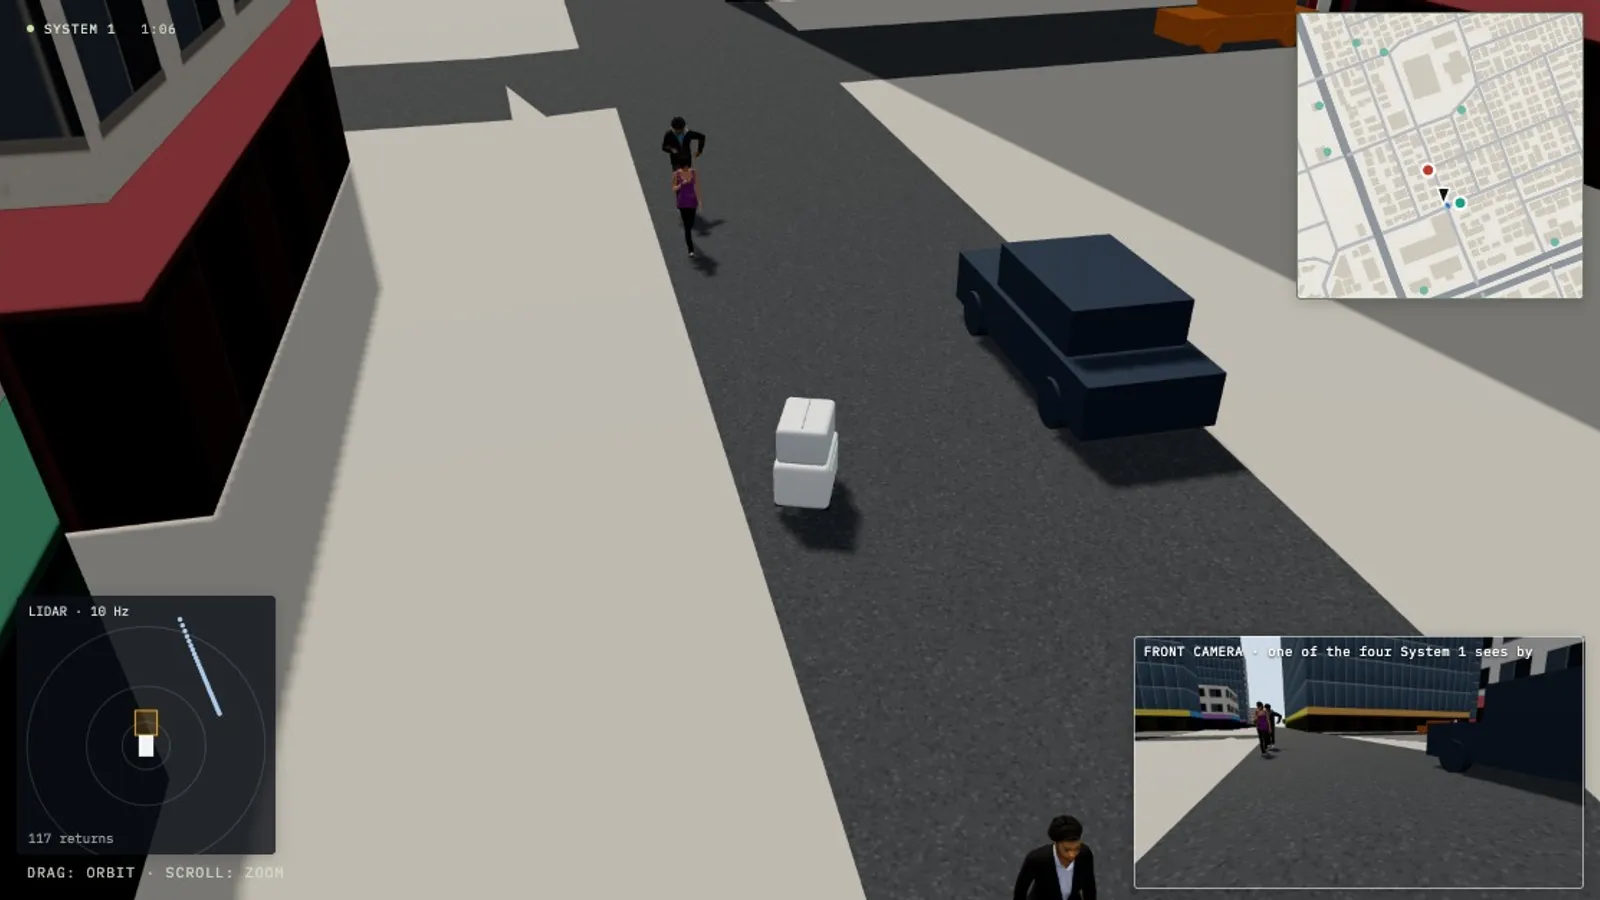 Delivers through the lunch crowd A sidewalk robot delivers on real Gangnam streets; System 1 picks every manoeuvre, pass and crossing, and calls the operator only when it must.TESTSA way through the crowd, and when to call the operator.
Only the decision model changes.
Every environment splits the robot’s work into three layers. The task and the executor stay fixed; the decision model between them is the one you choose.
Sets the goal and the order of work: the tables to serve, the tubes to prepare, the order to deliver.
Reads the robot’s state as it moves and answers typed questions: what next, who first, wait or go.
Carries each answer out with the environment’s own controllers.
Every model gets the same state, the same questions and the same executor.
Robots ask as they move, once a second or faster. A late answer is carried out late.
Choice, score or yes/no, through OpenRouter’s Decisions API.
No model sees the simulator’s ground truth. Where a stand-in replaces a perception model, the environment’s page names it.
Choose one on any environment’s page.
The models the site runs answer through OpenRouter’s Decisions API. No scores yet: watch them decide.
A decision model served through OpenRouter’s Decisions API. It reads a description of the state and answers typed questions with probabilities.
Runs in all seven environments.
A decision model served through OpenRouter’s Decisions API. It reads a description of the state and answers typed questions with probabilities.
Runs in all seven environments.
A decision model served through OpenRouter’s Decisions API. It reads a description of the state and answers typed questions with probabilities.
Runs in all seven environments.
A decision model served through OpenRouter’s Decisions API. It reads a description of the state and answers typed questions with probabilities.
Runs in all seven environments.
A decision model served through OpenRouter’s Decisions API. It reads a description of the state and answers typed questions with probabilities.
Runs in all seven environments.
Steerix Robotics’ own decision model, made for physical judgment, and open source. Steerix serves it directly rather than through OpenRouter, so its calls take another network path than the other models’, and turns it on for bench runs; while it is off, it cannot be chosen.
It runs in all seven environments.
Steerix Robotics also runs this bench. robo-jev runs on the same harness as every other model.
Any model that answers OpenRouter’s Decisions API can run in every environment.