ROBO-JEV · BY STEERIX ROBOTICS · OPEN SOURCE
A fast, single-pass 2B System 1 for robots’ physical judgment.
robo-jev reads a short text of what a robot senses and answers the questions that matter in the moment — will the glass tip if I brake now? does the person reach my path first? did the part seat? — with a probability for every answer.
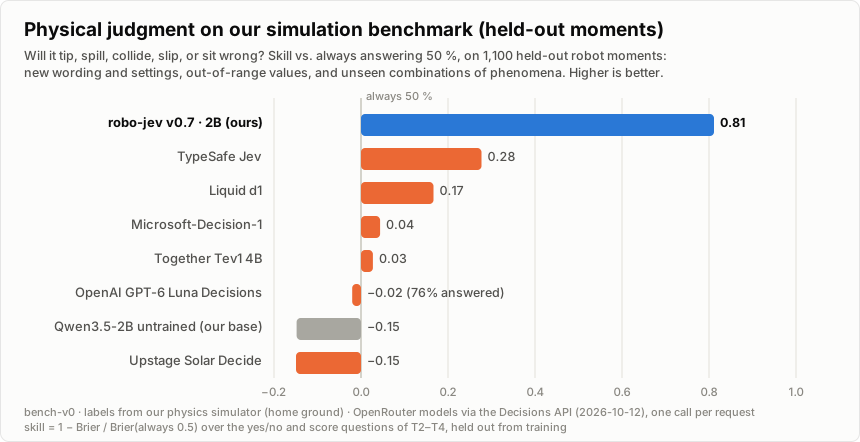
Benchmark
| Model | Physical judgment ↑ | General reading (BoolQ + MultiNLI) ↑ |
|---|---|---|
| robo-jev v0.7 · 2B | 0.81 | 0.71 |
| TypeSafe Jev | 0.28 | 0.91 |
| Liquid d1 | 0.17 | 0.93 |
| Microsoft-Decision-1 | 0.04 | 0.92 |
| Together Tev1 4B | 0.03 | 0.90 |
| OpenAI GPT-6 Luna Decisions | −0.02 ¹ | 0.86 |
| Upstage Solar Decide | −0.15 | 0.86 |
| Qwen3.5-2B, untrained | −0.15 | 0.74 |
- Physical judgment is skill against always answering 50 % (0 = a coin flip, 1 = perfect) on robo-jev’s physical-judgment benchmark: 1,100 held-out situations — wordings, value ranges and combinations of phenomena the model never saw in training. The decision models were asked through the OpenRouter Decisions API.
- ¹ OpenAI GPT-6 Luna Decisions declined about a fifth of the physical-judgment requests; its score covers the rest.
Why it matters
- 01
Fast
One forward pass per question — no sampling, no reasoning tokens. On one L4 GPU a short request answers in about 50 ms, a dozen questions in about 0.1 s.
- 02
Small
2B parameters: it runs beside a robot’s planner on a single small GPU.
- 03
Drop-in
The Decisions API’s request shape — a state text and up to 12 questions — and a calibrated probability for every answer.
Limits and links
Limits: choice questions with 2–466 options; 1–12 questions per request; state text ≤ 16,000 characters. Options past the 26th get two-letter codes (AA, AB, …) that were not part of training, and the model almost never picks them in the default order.
Research preview, tuned on simulated physical judgment; less reliable outside simulation, and not a safety system.
- Hugging FaceSteerix-org/robo-jev-2b — merged weights
- Hugging FaceSteerix-org/robo-jev-2b-lora — LoRA adapter for Qwen/Qwen3.5-2B
- robojev benchThe Bench tab — the robot environments it runs in beside the other decision models
- GitHubSTEERIX-home/robo-jev — the simulation engine that makes the training data, the training and scoring tools, and the benchmark
robo-jev is built by Steerix Robotics, which also runs robojev bench. When it runs in the bench, it runs on the same harness as every other model.
License: Apache License 2.0. Copyright 2026 Steerix Robotics.
THIS PAGE FOLLOWS THE ROBO-JEV README AT 88653E1 (2026-10-16)